MR-ESC-AM32 overview
The MR-ESC-AM32 is the electronic speed controller (ESC) reference design of the NXP Mobile Robotics family. It is a brushless DC (BLDC) motor controller based on the open-source AM32 firmware and implemented with an NXP MCX A microcontroller. It is designed for drones, robotic vehicles, and other applications requiring sensorless BLDC motor control under the direction of an external flight controller or motor-control system. The board is intended as a validated ESC starting point that customers can evaluate, reproduce, and customize for their own vehicles.
The controller is built around an NXP MCXA133 microcontroller, an Arm Cortex-M33 MCU running the NXP port of the AM32 firmware. It implements six-step commutation using back-EMF (BEMF) zero-cross detection and accepts RC-PWM, DShot, and bidirectional DShot control interfaces.
Functional block diagram
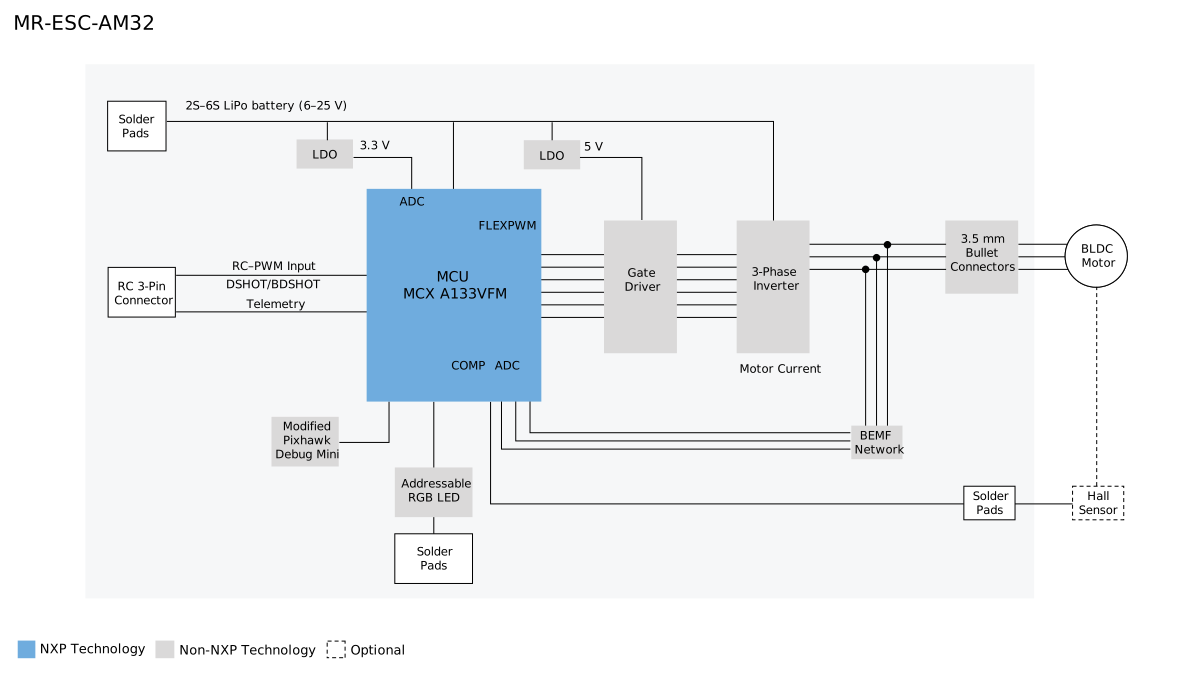
Figure 1. MR-ESC-AM32 functional block diagram
Main components
The reference design integrates the following main components and interfaces:
NXP MCXA133 microcontroller (Arm Cortex-M33) running the AM32 firmware
DRV8300N three-phase gate driver and a MOSFET-based power stage
Sensorless BEMF-detection network for six-step commutation
RC-PWM, DShot, and bidirectional DShot control interfaces
KISS-format serial telemetry (TX) output
Addressable RGB status LED and a modified Pixhawk debug connector
Optional Hall-sensor / quadrature-encoder solder pads (hardware provision only)
NXP also provides the complete hardware Bill of Materials and design files, enabling customers to evaluate, reproduce, and customize the reference platform for their own products.
For overview information, documentation, software, tools, and ordering details, see the MR-ESC-AM32 product page on the NXP web site.